
Ground Robotics
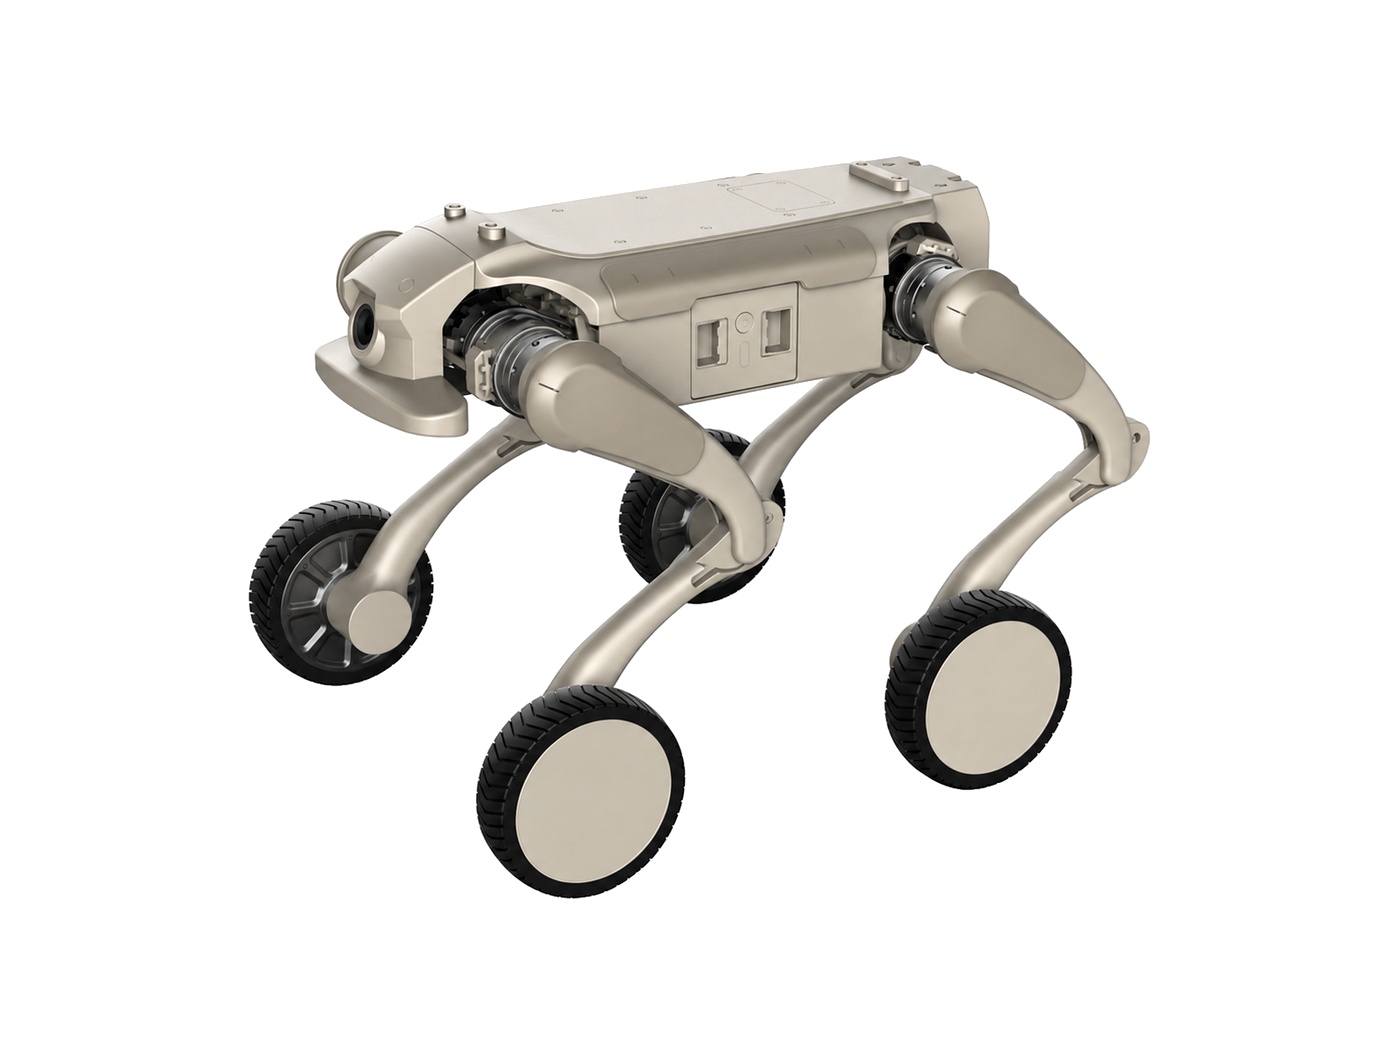
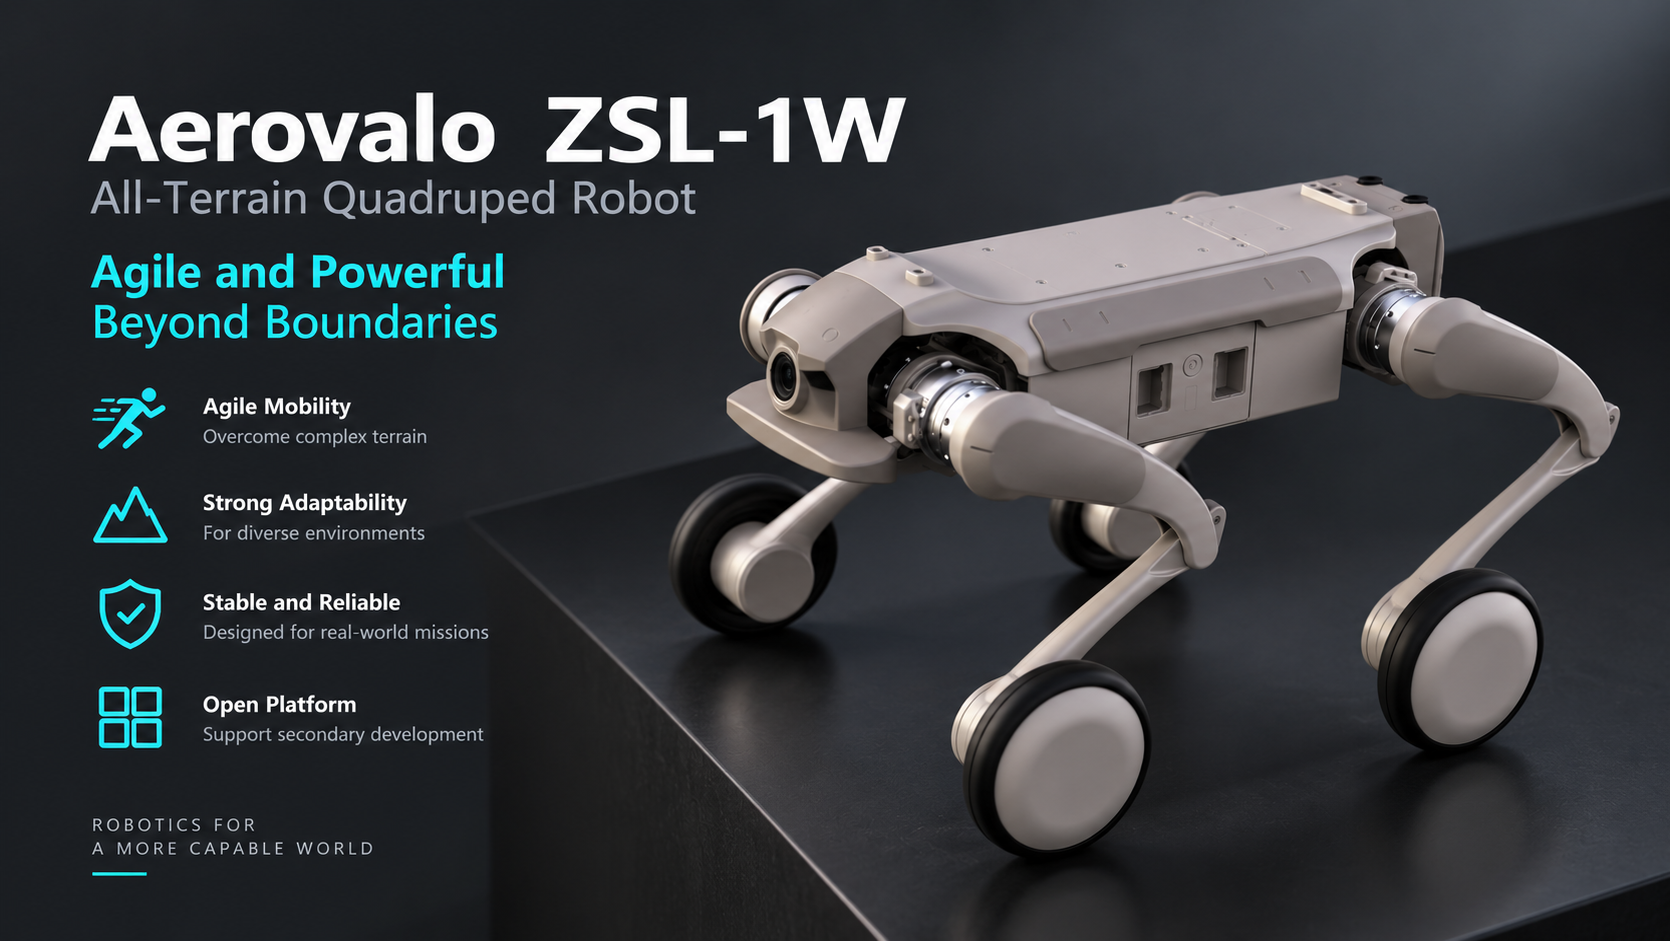
Gangbeng L1-W Wheeled Quadruped Robot
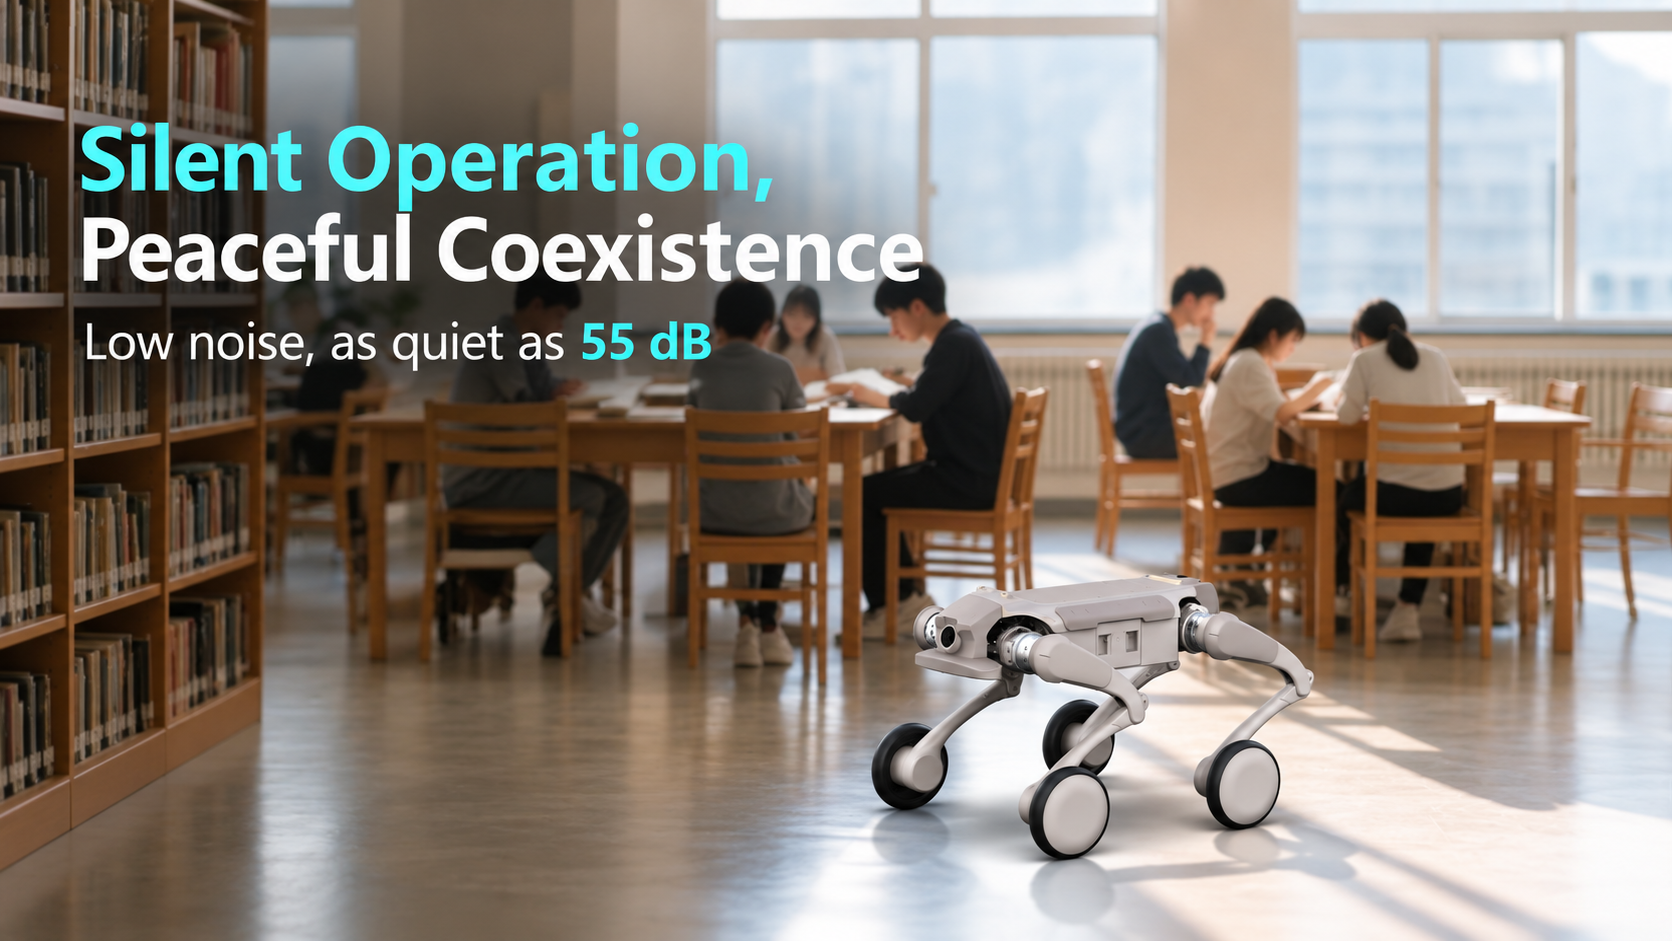
A 22 kg wheeled quadruped platform that combines agile legged mobility with four independent wheel drives. The L1-W supports long-range inspection, patrol, all-terrain traversal, payload integration, and secondary development for field robotics.
ZSL-1W
Technical Specifications
- Degrees of Freedom
- 12 DOF
- Standing Dimensions
- Approx. 630 x 430 x 485 mm
- Prone Dimensions
- Approx. 690 x 540 x 165 mm
- Weight
- 22 kg
- Operating Time
- 1 to 2 hours
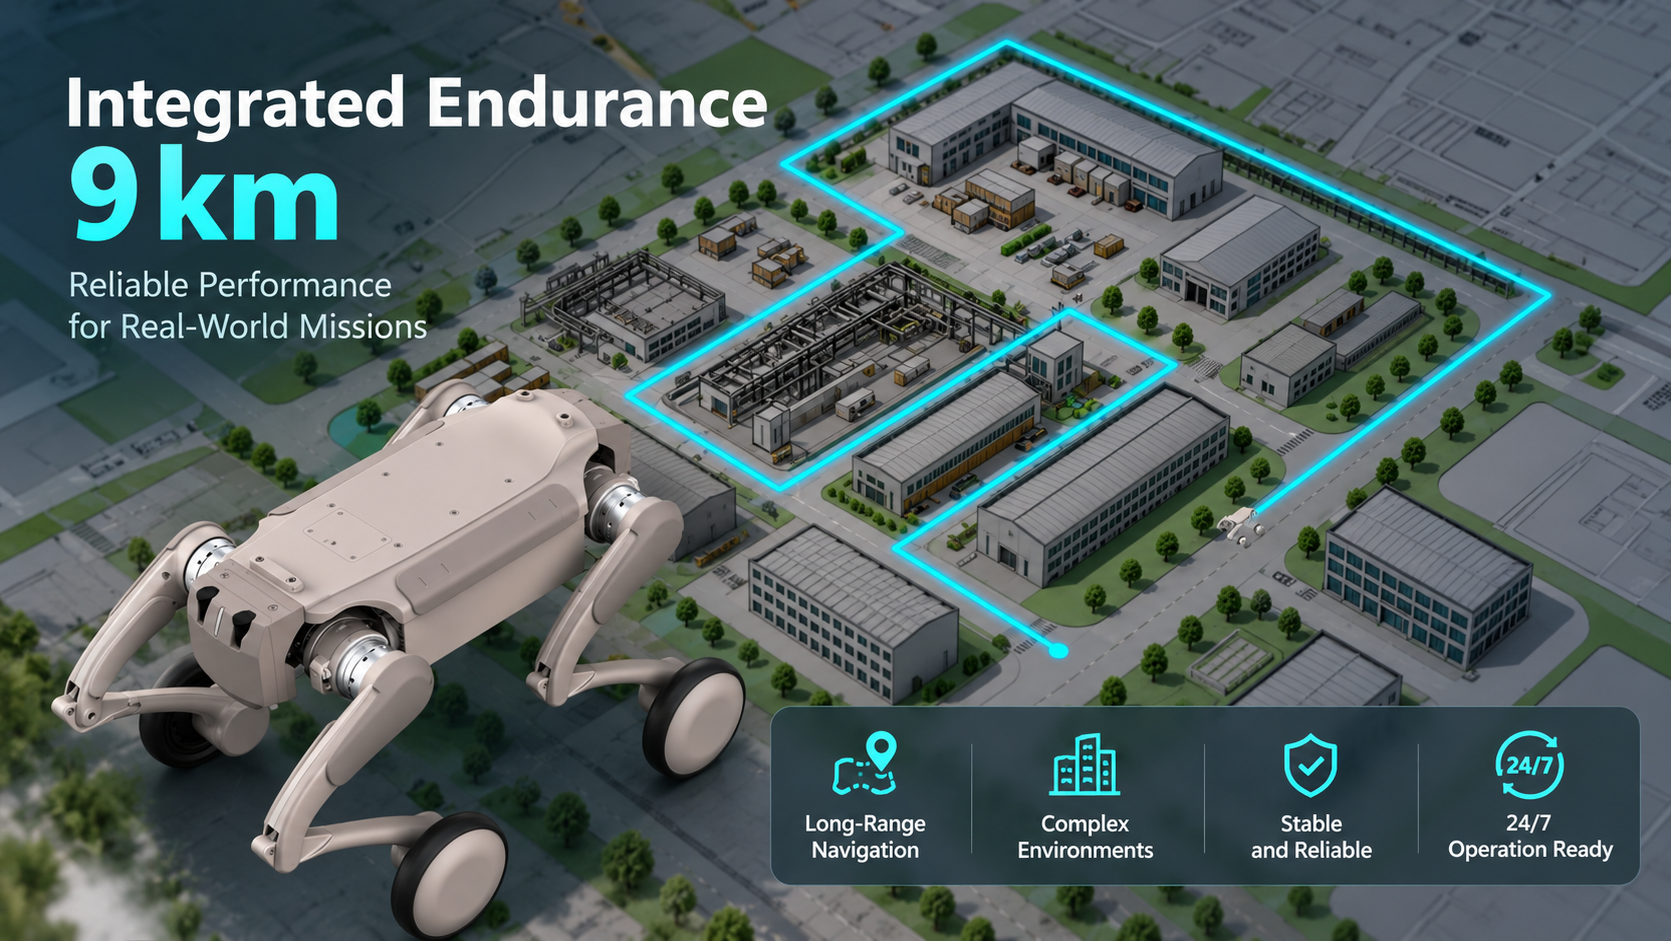
- Maximum Range
- 9 km
- Continuous Stair Height
- 16 cm
- Maximum Climb Angle
- 30° standard; up to 40° maximum
- Maximum Speed
- 3.7 m/s standard; up to 5.5 m/s
- Payload
- Approx. 10 kg; up to 12 kg maximum
- Battery
- 5 Ah nominal; 4.6 Ah rated; 43.2 V
- Operating Temperature
- 0°C to 40°C
- Protection Rating
- IP54
- Onboard Computing
- High-performance 8-core CPU
- Interfaces
- Ethernet, USB, power, SBUS, and UART
- Secondary Development
- Supported
- Maximum Step / Drop Height
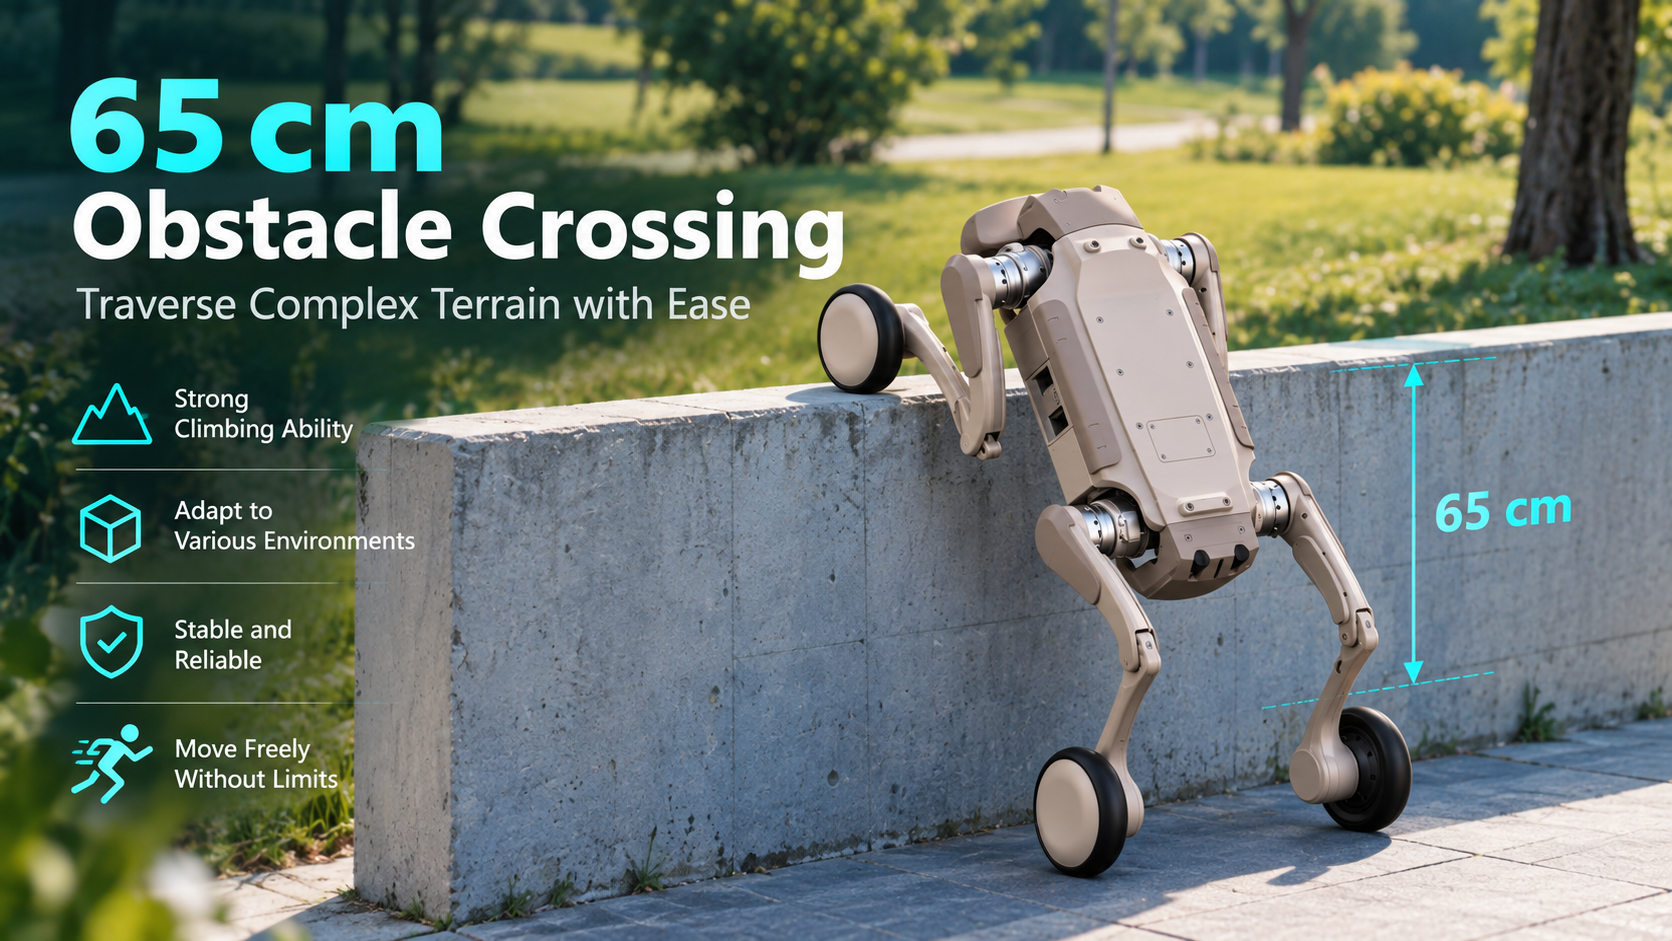
- 60 cm
- Precision Joint Motors
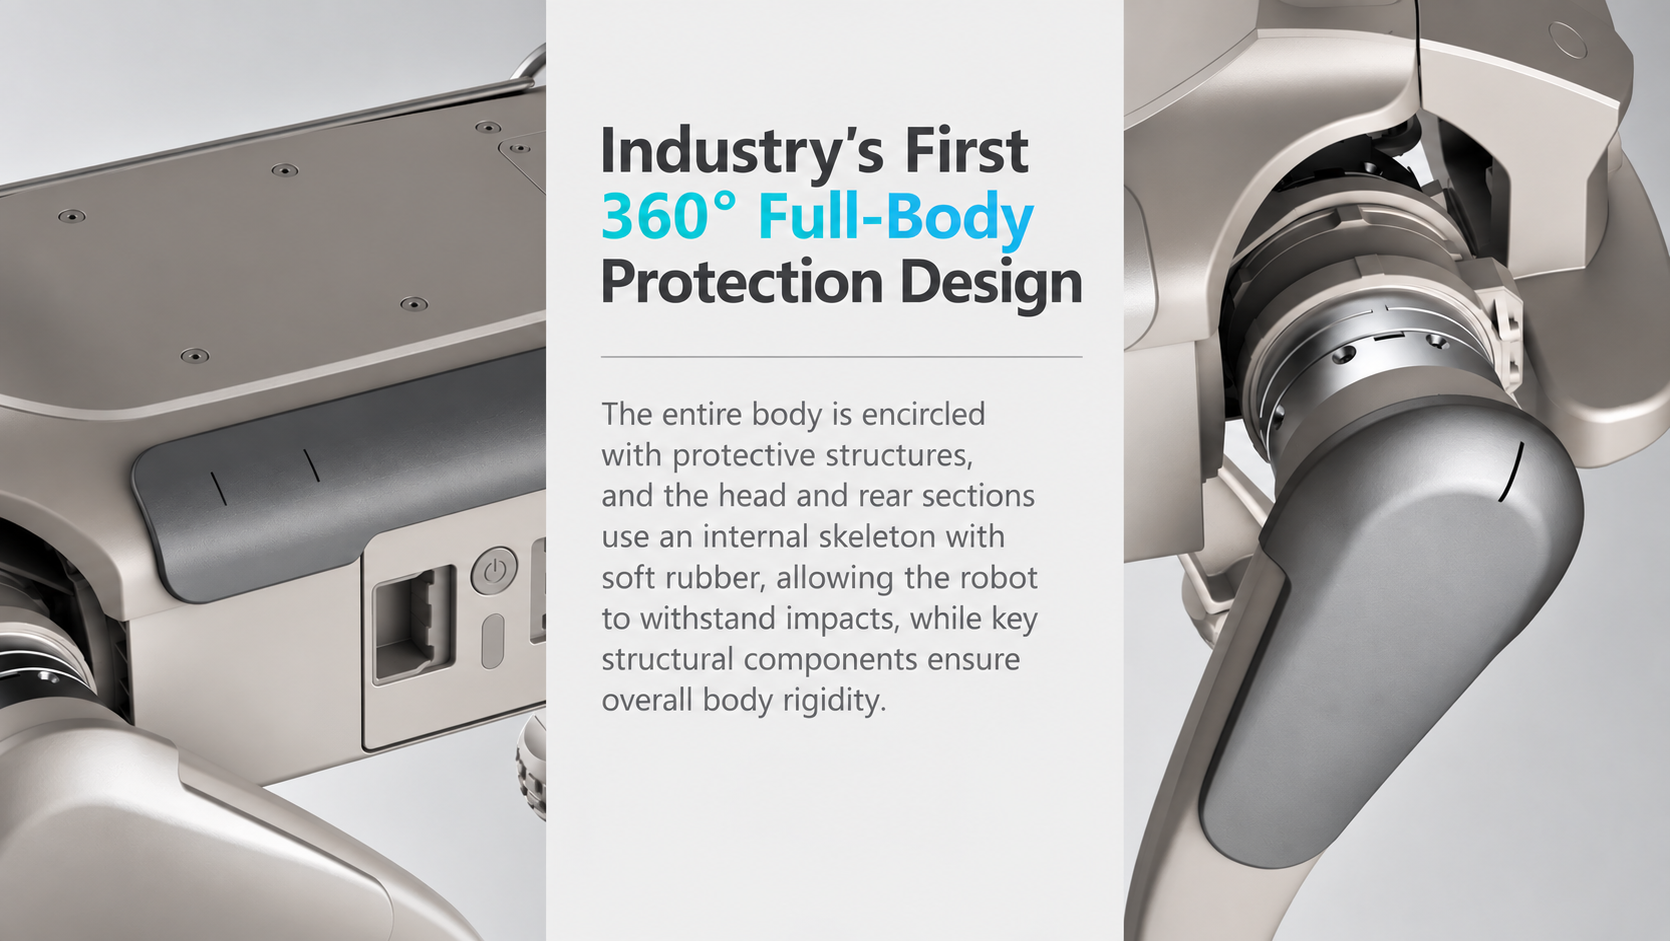
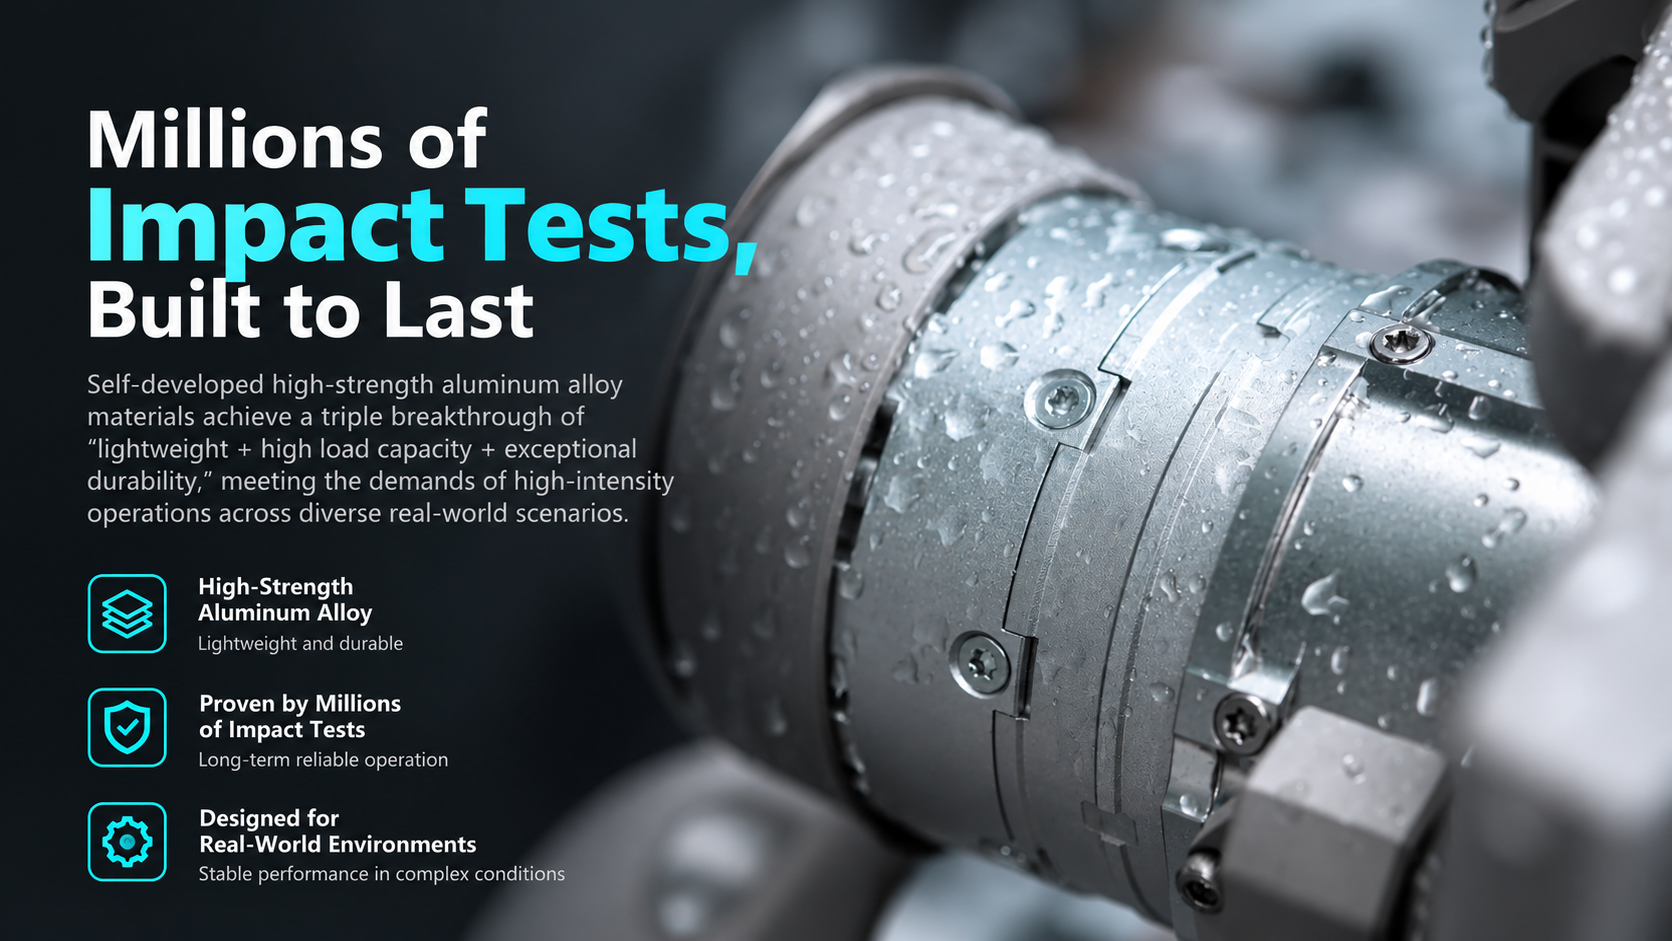
- 12 aluminum-alloy joint motors
- Wheel Hub Motors
- 4 high-performance motors
- Tires
- 6-inch solid tires
RFQ
Ask about Gangbeng L1-W.
Send your target application, required payload, operating environment, quantity, and integration requirements. We can recommend the matching L1-W configuration for inspection, patrol, development, or long-range field robotics projects.
- Ground robot configuration and accessory support
- Sensor, compute, positioning, and communication integration
- Export-ready packaging and documentation